On Going!
MILO Robot
A free-roaming quadruped robot.
About the project
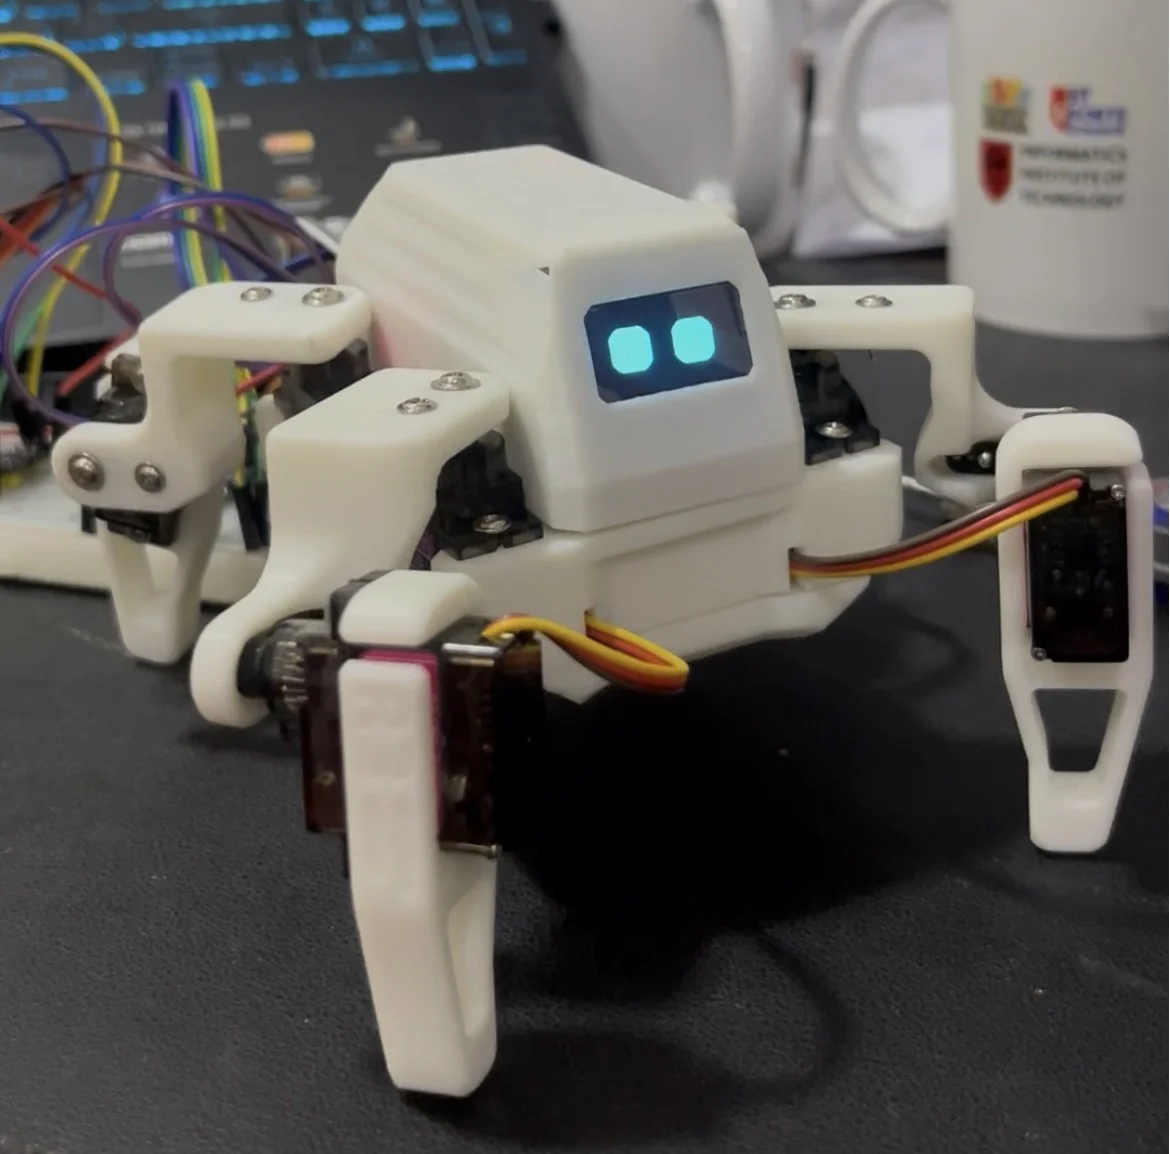
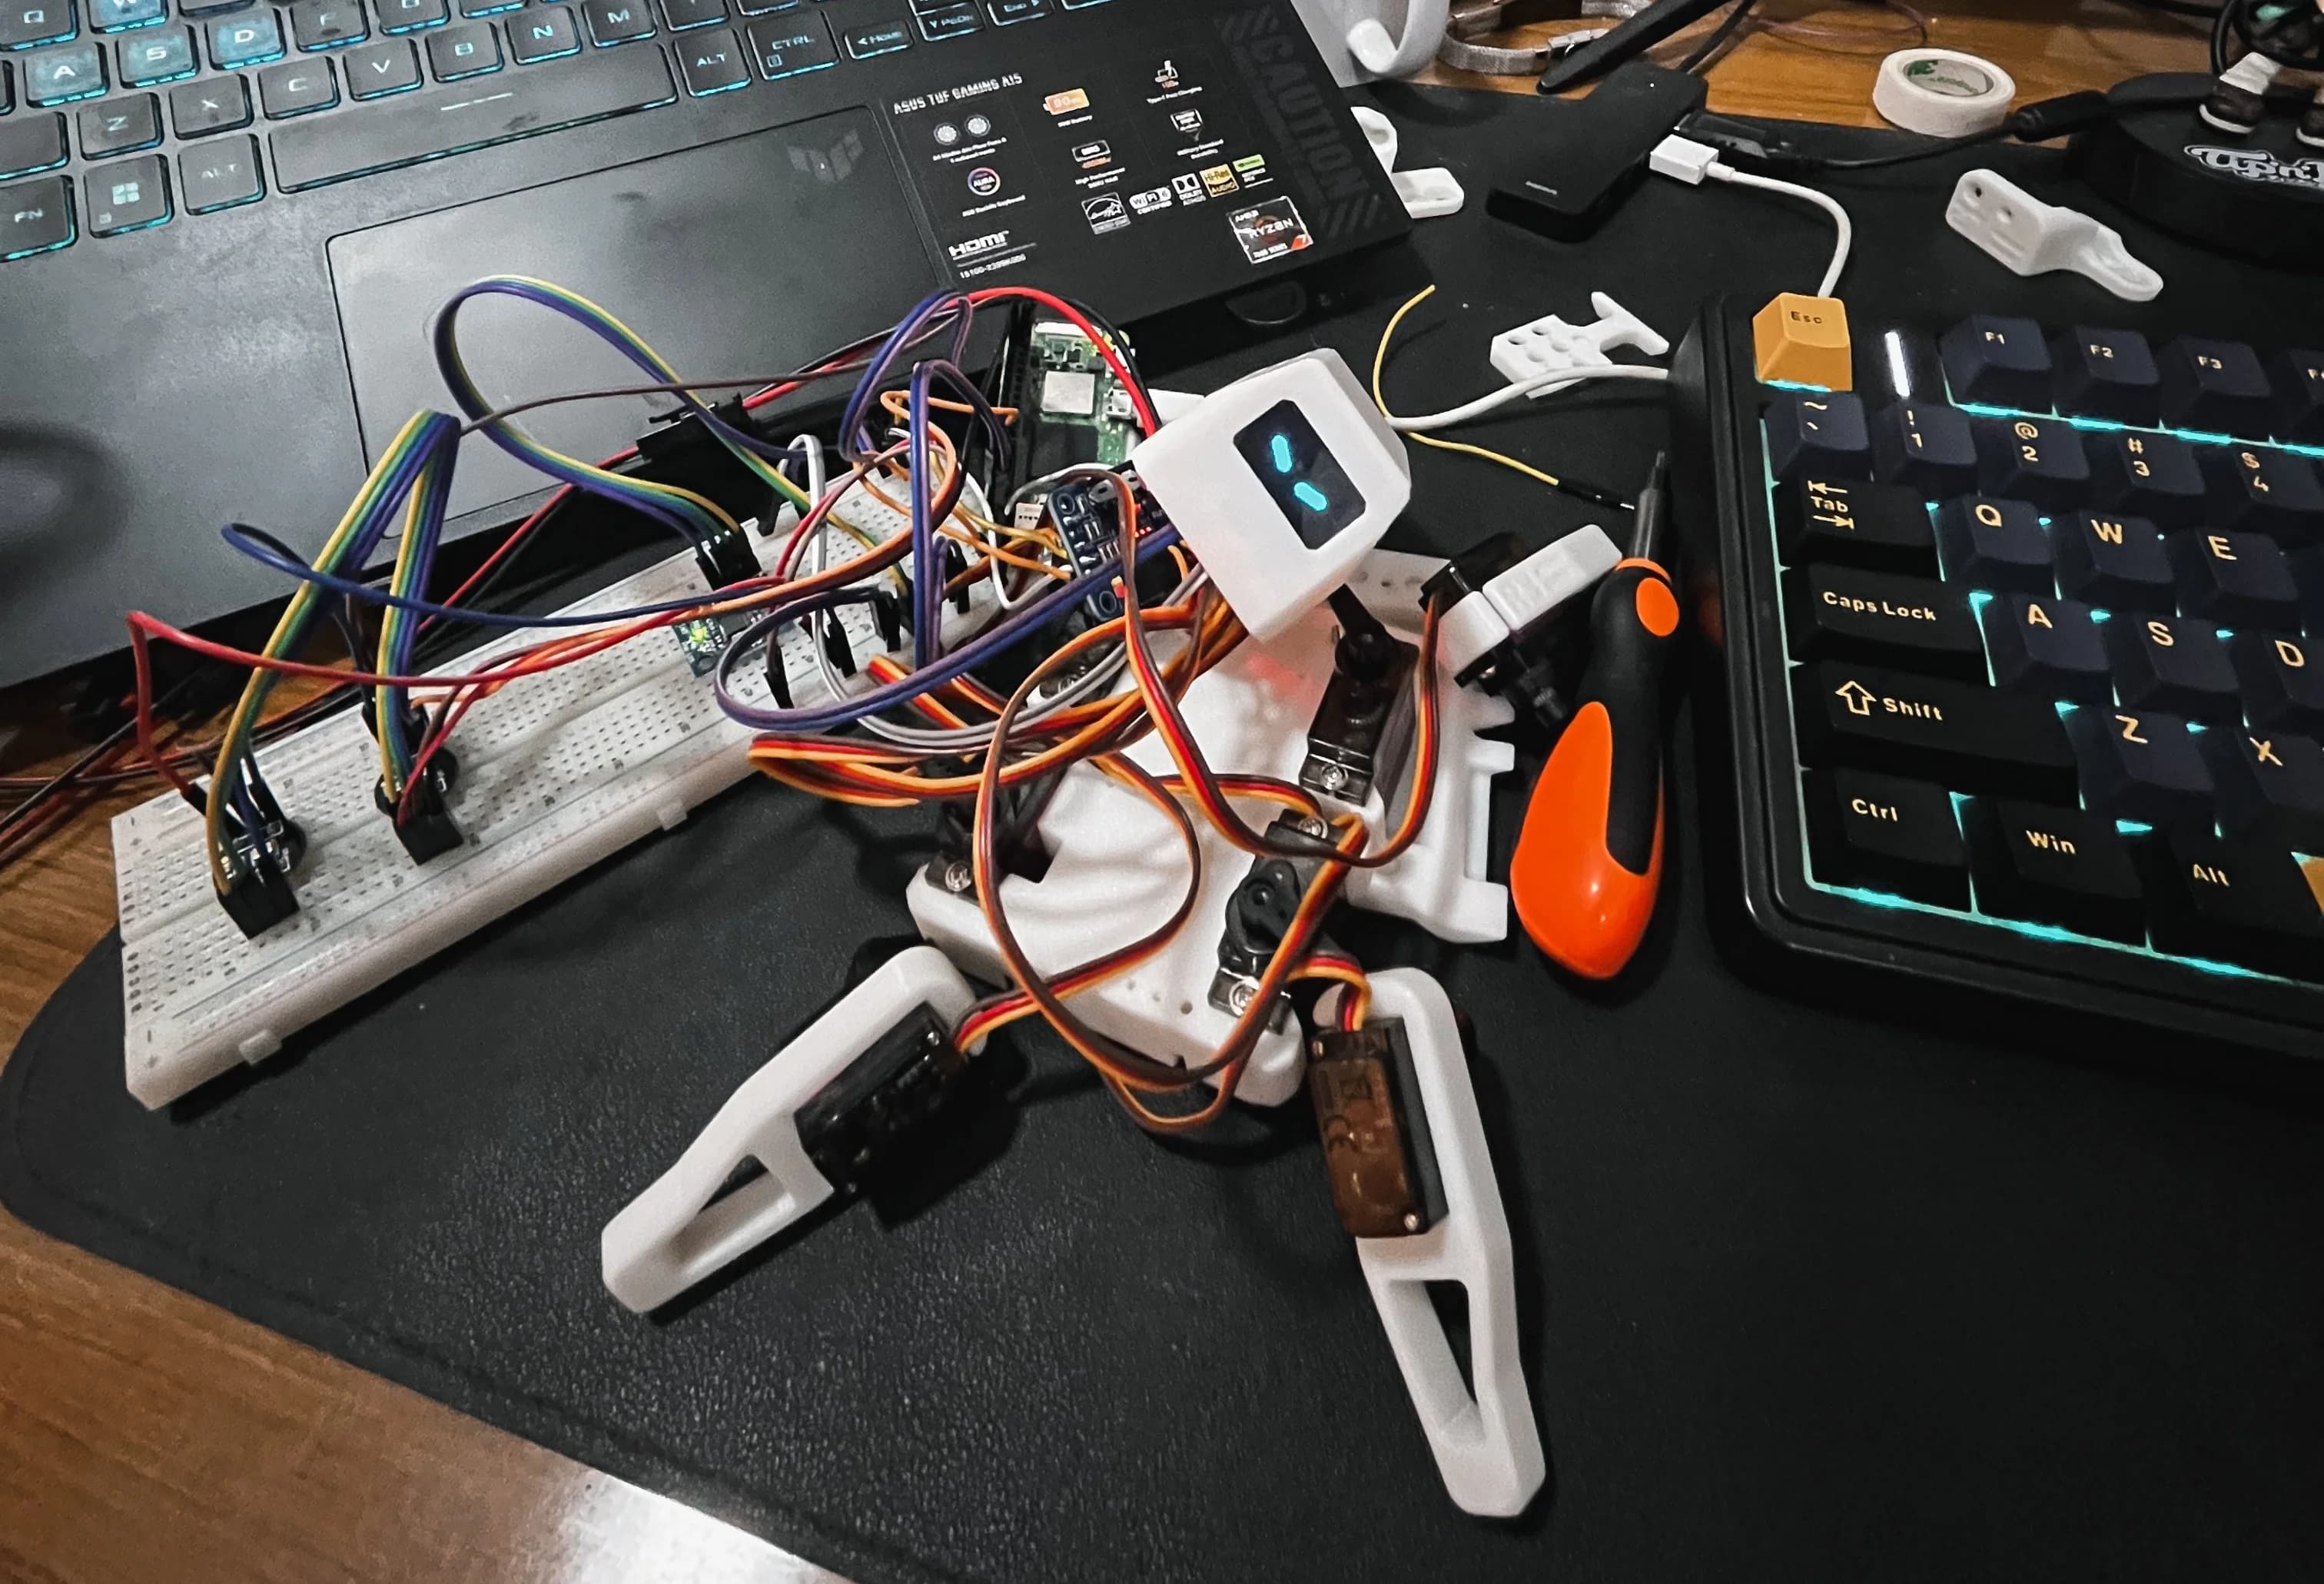
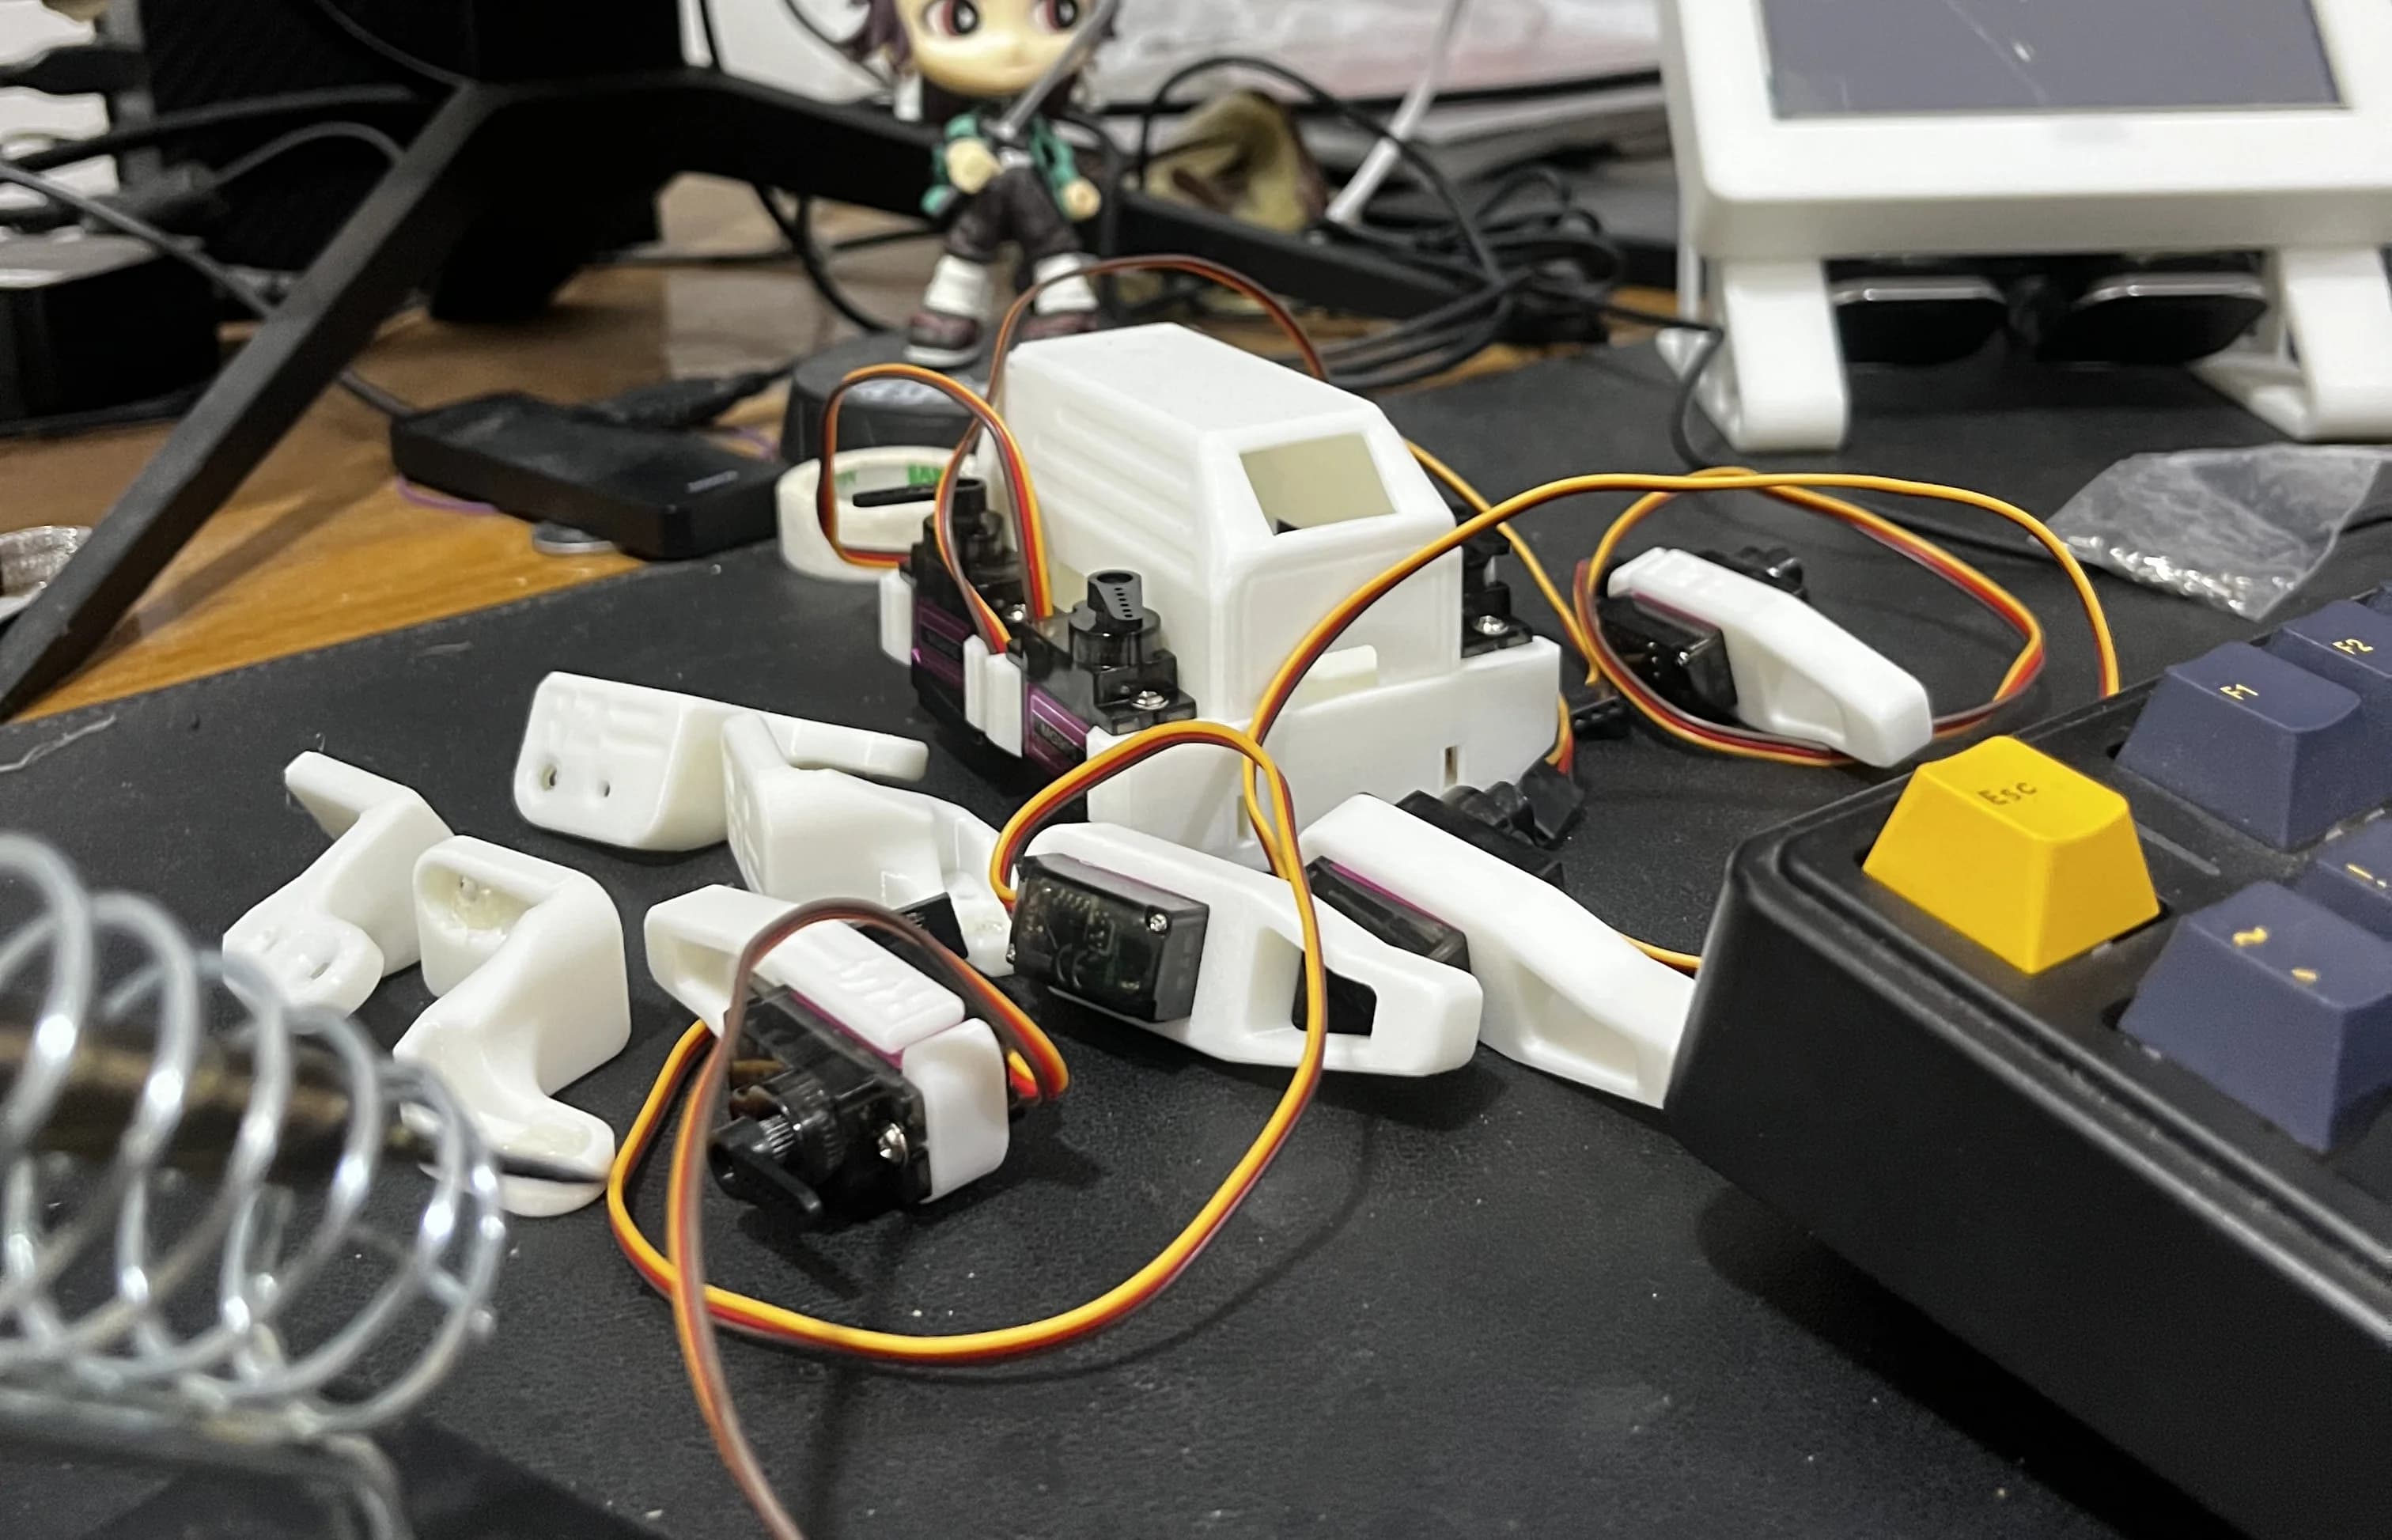
I built MILO, a free-roaming quadruped robot that walks with a neural net, remembers you, and borrows brains. It keeps Sesame's 3D-printed frame, 8× MG90 servo layout, and expressive OLED face, and replaces everything else: the ESP32 gives way to a Raspberry Pi Zero 2W with a camera, stereo microphones, a speaker, and an IMU. MILO walks with a reinforcement-learning-trained neural network, stores everyone it meets in an on-robot knowledge graph, and gets its intelligence (LLM, speech, vision) from any GPU machine on your LAN running the Milo Brain desktop app.
View source on GitHubTechnologies
- Python
- Raspberry Pi Zero 2W
- Neural Network
- Reinforcement Learning
- SQLite
- WebSocket
- mDNS
- Apache 2.0
- I2C
- I2S
- Ollama
- Piper TTS
- Textual TUI
- Python 3.11
- WebSocket protocol
- Vision
- Knowledge Graphs
Gallery